Pesticide Sprayer Spider Robot with Grass Cutter
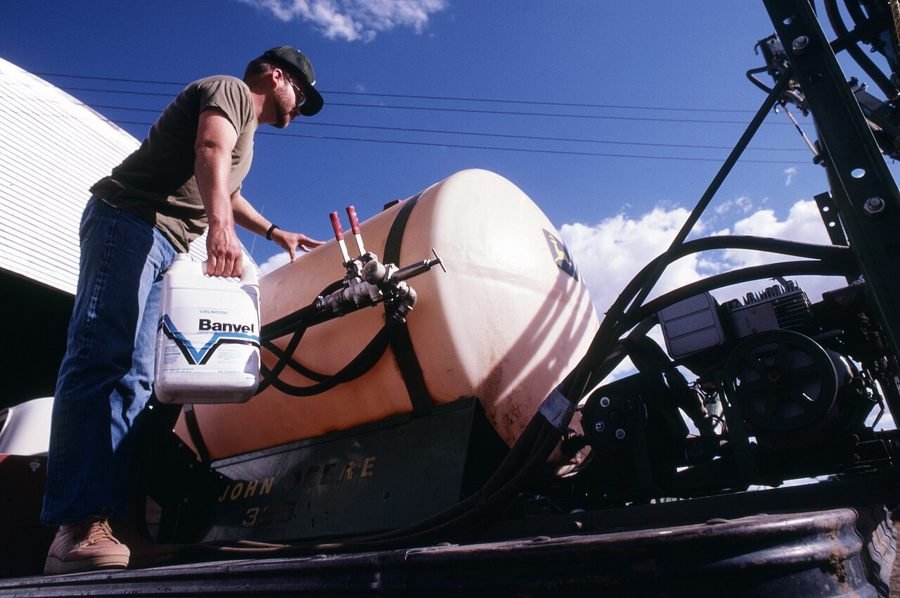
Image: Filling sprayer tank on tractor with Banvel (1985).jpg by USDA NRCS via Wikimedia Commons, Public domain
Manual pesticide spraying on farmland is imprecise: chemicals get applied uniformly across a field regardless of whether a patch is crop or weed, wasting pesticide, raising input costs, and exposing farm workers to unnecessary chemical contact. Uneven terrain in small and mid-sized farms also makes wheeled sprayers difficult to maneuver consistently.
This project builds a remotely operated, multi-legged ("spider") robot that combines targeted pesticide spraying with mechanical weed clearing in a single pass. An onboard camera and color/IR sensor pair let the controller distinguish healthy crop foliage from weeds in real time, so the spray nozzle only activates over weed-covered patches instead of blanket-spraying the whole field. A front-mounted rotary cutting motor removes low weeds and grass mechanically wherever spraying alone isn't enough, and a compact onboard chemical tank keeps the chassis light and easy to refill between rows.
How It Works
- The robot's legs (or, in a simplified build, a low-ground-clearance wheeled chassis) let it move steadily across uneven, unpaved field surfaces under RF or Bluetooth remote control.
- A forward-facing camera module feeds frames to the controller, which uses basic colour-thresholding (or a lightweight vision model on a Raspberry Pi variant) to flag weed-density regions distinct from crop rows.
- When a weed region is detected directly ahead, the controller energizes a relay that runs a small submersible pump, drawing pesticide from the onboard tank through a nozzle aimed at that patch only.
- The front-mounted cutting motor and blade assembly can be engaged independently to trim grass and low weeds mechanically, giving the robot a dual spray-and-cut mode for denser overgrowth.
- A float-level sensor in the tank flags low chemical levels on the controller/remote, reducing the chance of the robot running dry mid-row and needing a full stop-and-check.
Components
Arduino Uno/Mega (or ESP32 for onboard Wi-Fi telemetry)
ESP32-CAM or similar camera module for crop/weed differentiation
Color or IR reflectance sensor (secondary detection input)
DC gear motors + wheels or servo-driven leg linkages (spider chassis)
Motor driver module (L298N / BTS7960)
Mini submersible pump + spray nozzle + relay module
Small pesticide/water tank with float-level sensor
DC cutting motor with rotary blade guard
RF or Bluetooth (HC-05) remote control module
Li-ion/LiPo battery pack + chassis frame
Applications
- Precision spraying on small and mid-sized farms
- Nursery and greenhouse weed and pest management
- Reducing farm worker exposure to chemical sprays
- Combined lawn and field maintenance in one machine
Advantages
- Targeted spraying cuts pesticide usage and input cost compared to blanket spraying
- Dual spray + cut functionality removes the need for two separate machines
- Remote operation keeps the operator clear of chemical drift
- Low-clearance, multi-point contact chassis handles uneven farmland better than standard wheeled sprayers
Sample Code — Weed-Triggered Spray Relay
// Simplified spray-trigger logic — Arduino
// weedSensor: HIGH when the color/IR sensor flags a weed patch ahead
int weedSensor = 2;
int pumpRelay  = 7;
int cutterRelay = 8;
int tankFloatSwitch = 4; // LOW when tank level is low

void setup() {
  pinMode(weedSensor, INPUT);
  pinMode(tankFloatSwitch, INPUT_PULLUP);
  pinMode(pumpRelay, OUTPUT);
  pinMode(cutterRelay, OUTPUT);
  Serial.begin(9600);
}

void loop() {
  bool weedDetected = digitalRead(weedSensor) == HIGH;
  bool tankOk = digitalRead(tankFloatSwitch) == HIGH;

  if (weedDetected && tankOk) {
    digitalWrite(pumpRelay, HIGH);   // spray this patch only
    Serial.println("Weed detected -> spraying");
  } else {
    digitalWrite(pumpRelay, LOW);
  }

  if (!tankOk) {
    Serial.println("Tank level low - refill needed");
  }

  delay(150);
}
Related Research
- Precise Robotic Weed Spot-Spraying for Reduced Herbicide Usage and Improved Environmental Outcomes — arXiv
Hours
Monday - Saturday: 9:00 AM - 5:00 PM
Sunday: Not Working
Location
2nd Floor, Comptron Arcade, Kallattumukku,
Thiruvananthapuram, Kerala 695012
Book Now
+91 9633118080